Jens Lundell
Assistant Professor (tenure track) in Robotics and Machine Learning @ University of Turku.

I’m Jens Lundell, an Assistant Professor in Robotics at the University of Turku, Finland, where I founded the Manipulus Lab.
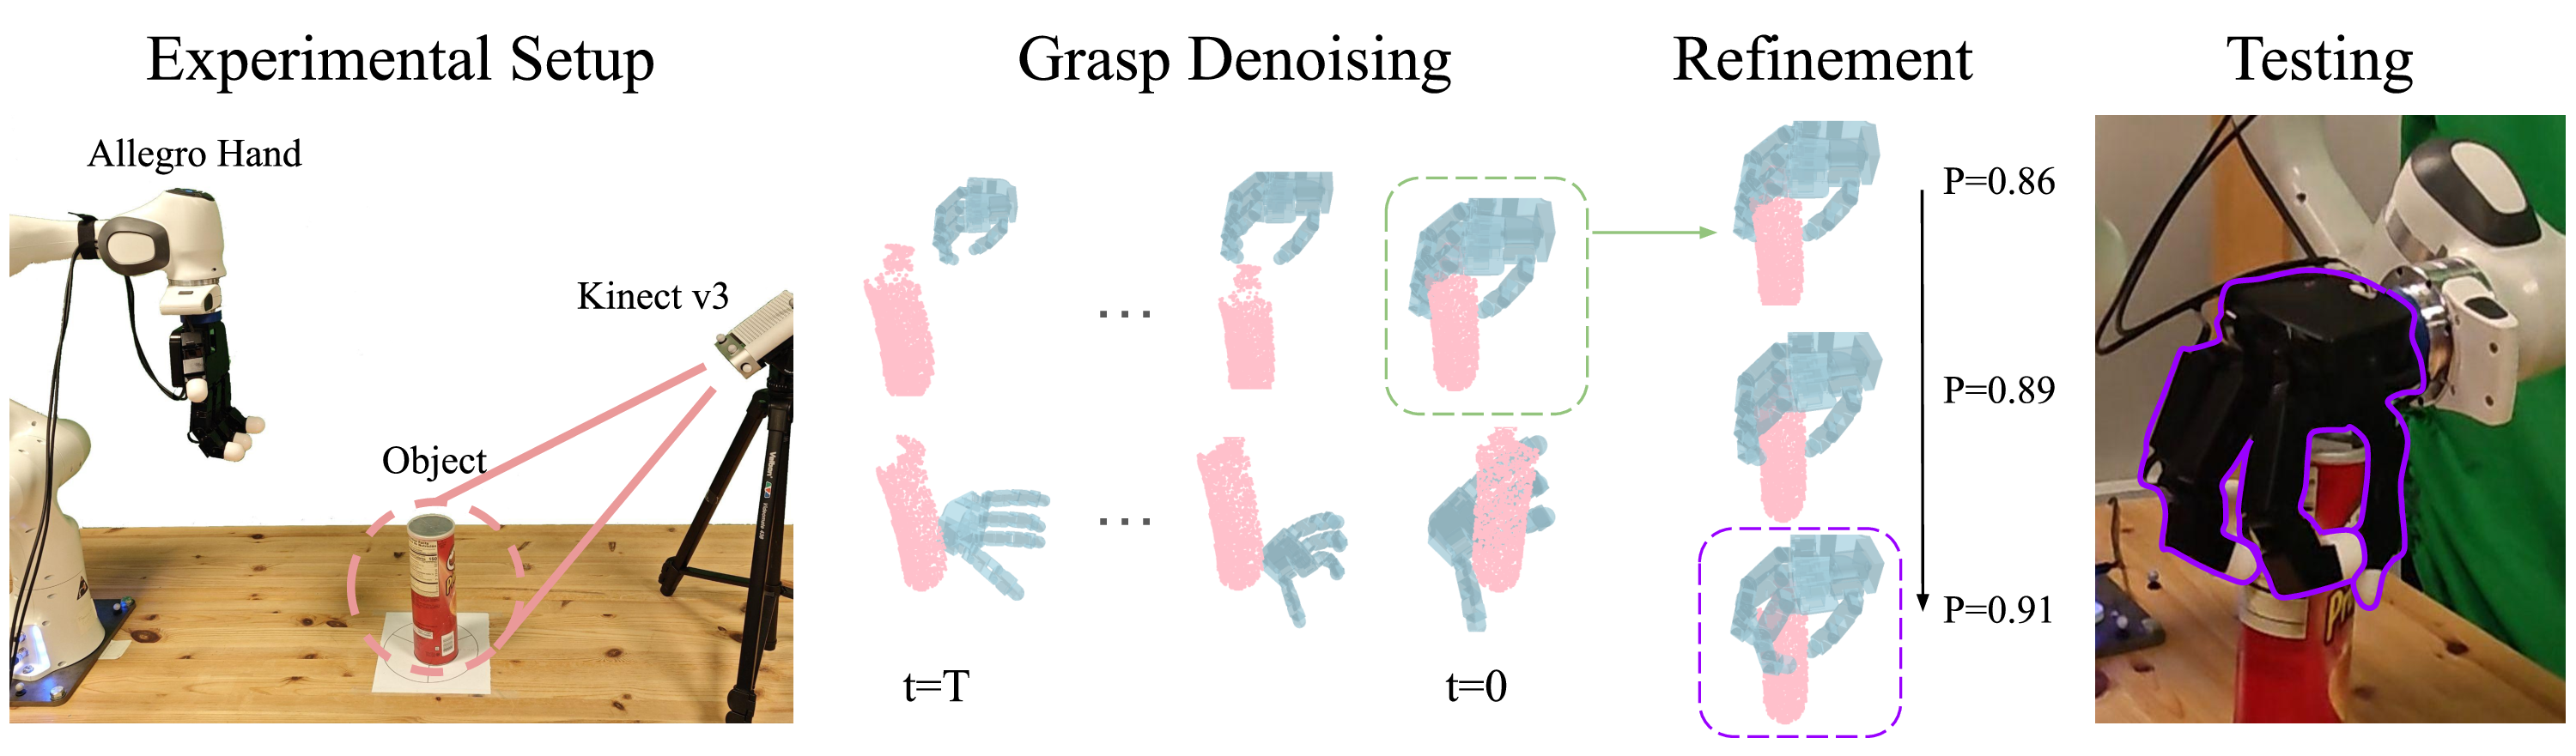
I work on how robots grasp and handle objects they cannot fully see, such as items in a cluttered pile or a garment folded over itself. I build generative models that propose grasps for two-finger grippers and multi-fingered hands, and methods that estimate the shape of cloth and other objects from camera images and touch. The selected papers below show examples.
At Turku I also work on vision-language-action (VLA) models, which turn camera images and written instructions into robot actions, so that one model can control robots with different grippers and hands.
Bio
I worked as a postdoctoral researcher from 2022-2025 with Danica Kragic in the Robotics, Perception and Learning Lab (RPL) at KTH in Stockholm, Sweden.
I did my Ph.D. in the Intelligent Robotics group at Aalto University (Finland) under the supervision of Prof. Ville Kyrki and Dr. Francesco Verdoja. My Ph.D. thesis addressed the problem of probabilistic 6-degree-of-freedom multi-finger grasping of objects in clutter. My solution was to explicitly shape-complete each object in the scene using deep learning, and plan grasps on those reconstructions. I also focused on using physics simulators to gather synthetic data for training deep networks.
I hold a dual Master’s degree in Space Science and Technology and Space Robotics and Automation from Aalto University and Luleå University of Technology (Sweden), and a Bachelor’s degree in Automation and Systems Technology from Aalto University.
Research Interests
- Probabilistic grasp synthesis in cluttered scenes,
- Generative models for robotic manipulation,
- Vision-language-action (VLA) models for robots with different grippers and hands,
- Cloth and deformable object state estimation,
- Visuo-haptic shape completion,
- Planning under uncertainty.
Prospective Students
I am currently not looking for PhD students. I do supervise Master’s thesis projects. The Teaching page lists the topics, example papers and what to send me.
News
| Oct 12, 2026 | Our preprint ClothAtlas: Joint Garment Identification and State Estimation under Self-Occlusion is now on arXiv. It identifies a garment and estimates its full shape when folds hide parts of it. See the project page for videos and results. |
|---|---|
| Aug 01, 2026 | I started an industry contract-research collaboration with Mirka Oy on robotic manipulation. The project applies Vision-Language-Action models, which map camera images and written instructions to robot actions. |
| Jun 26, 2026 | I served as the Opponent at the PhD defence of Kulunu Samarawickrama at Tampere University. |
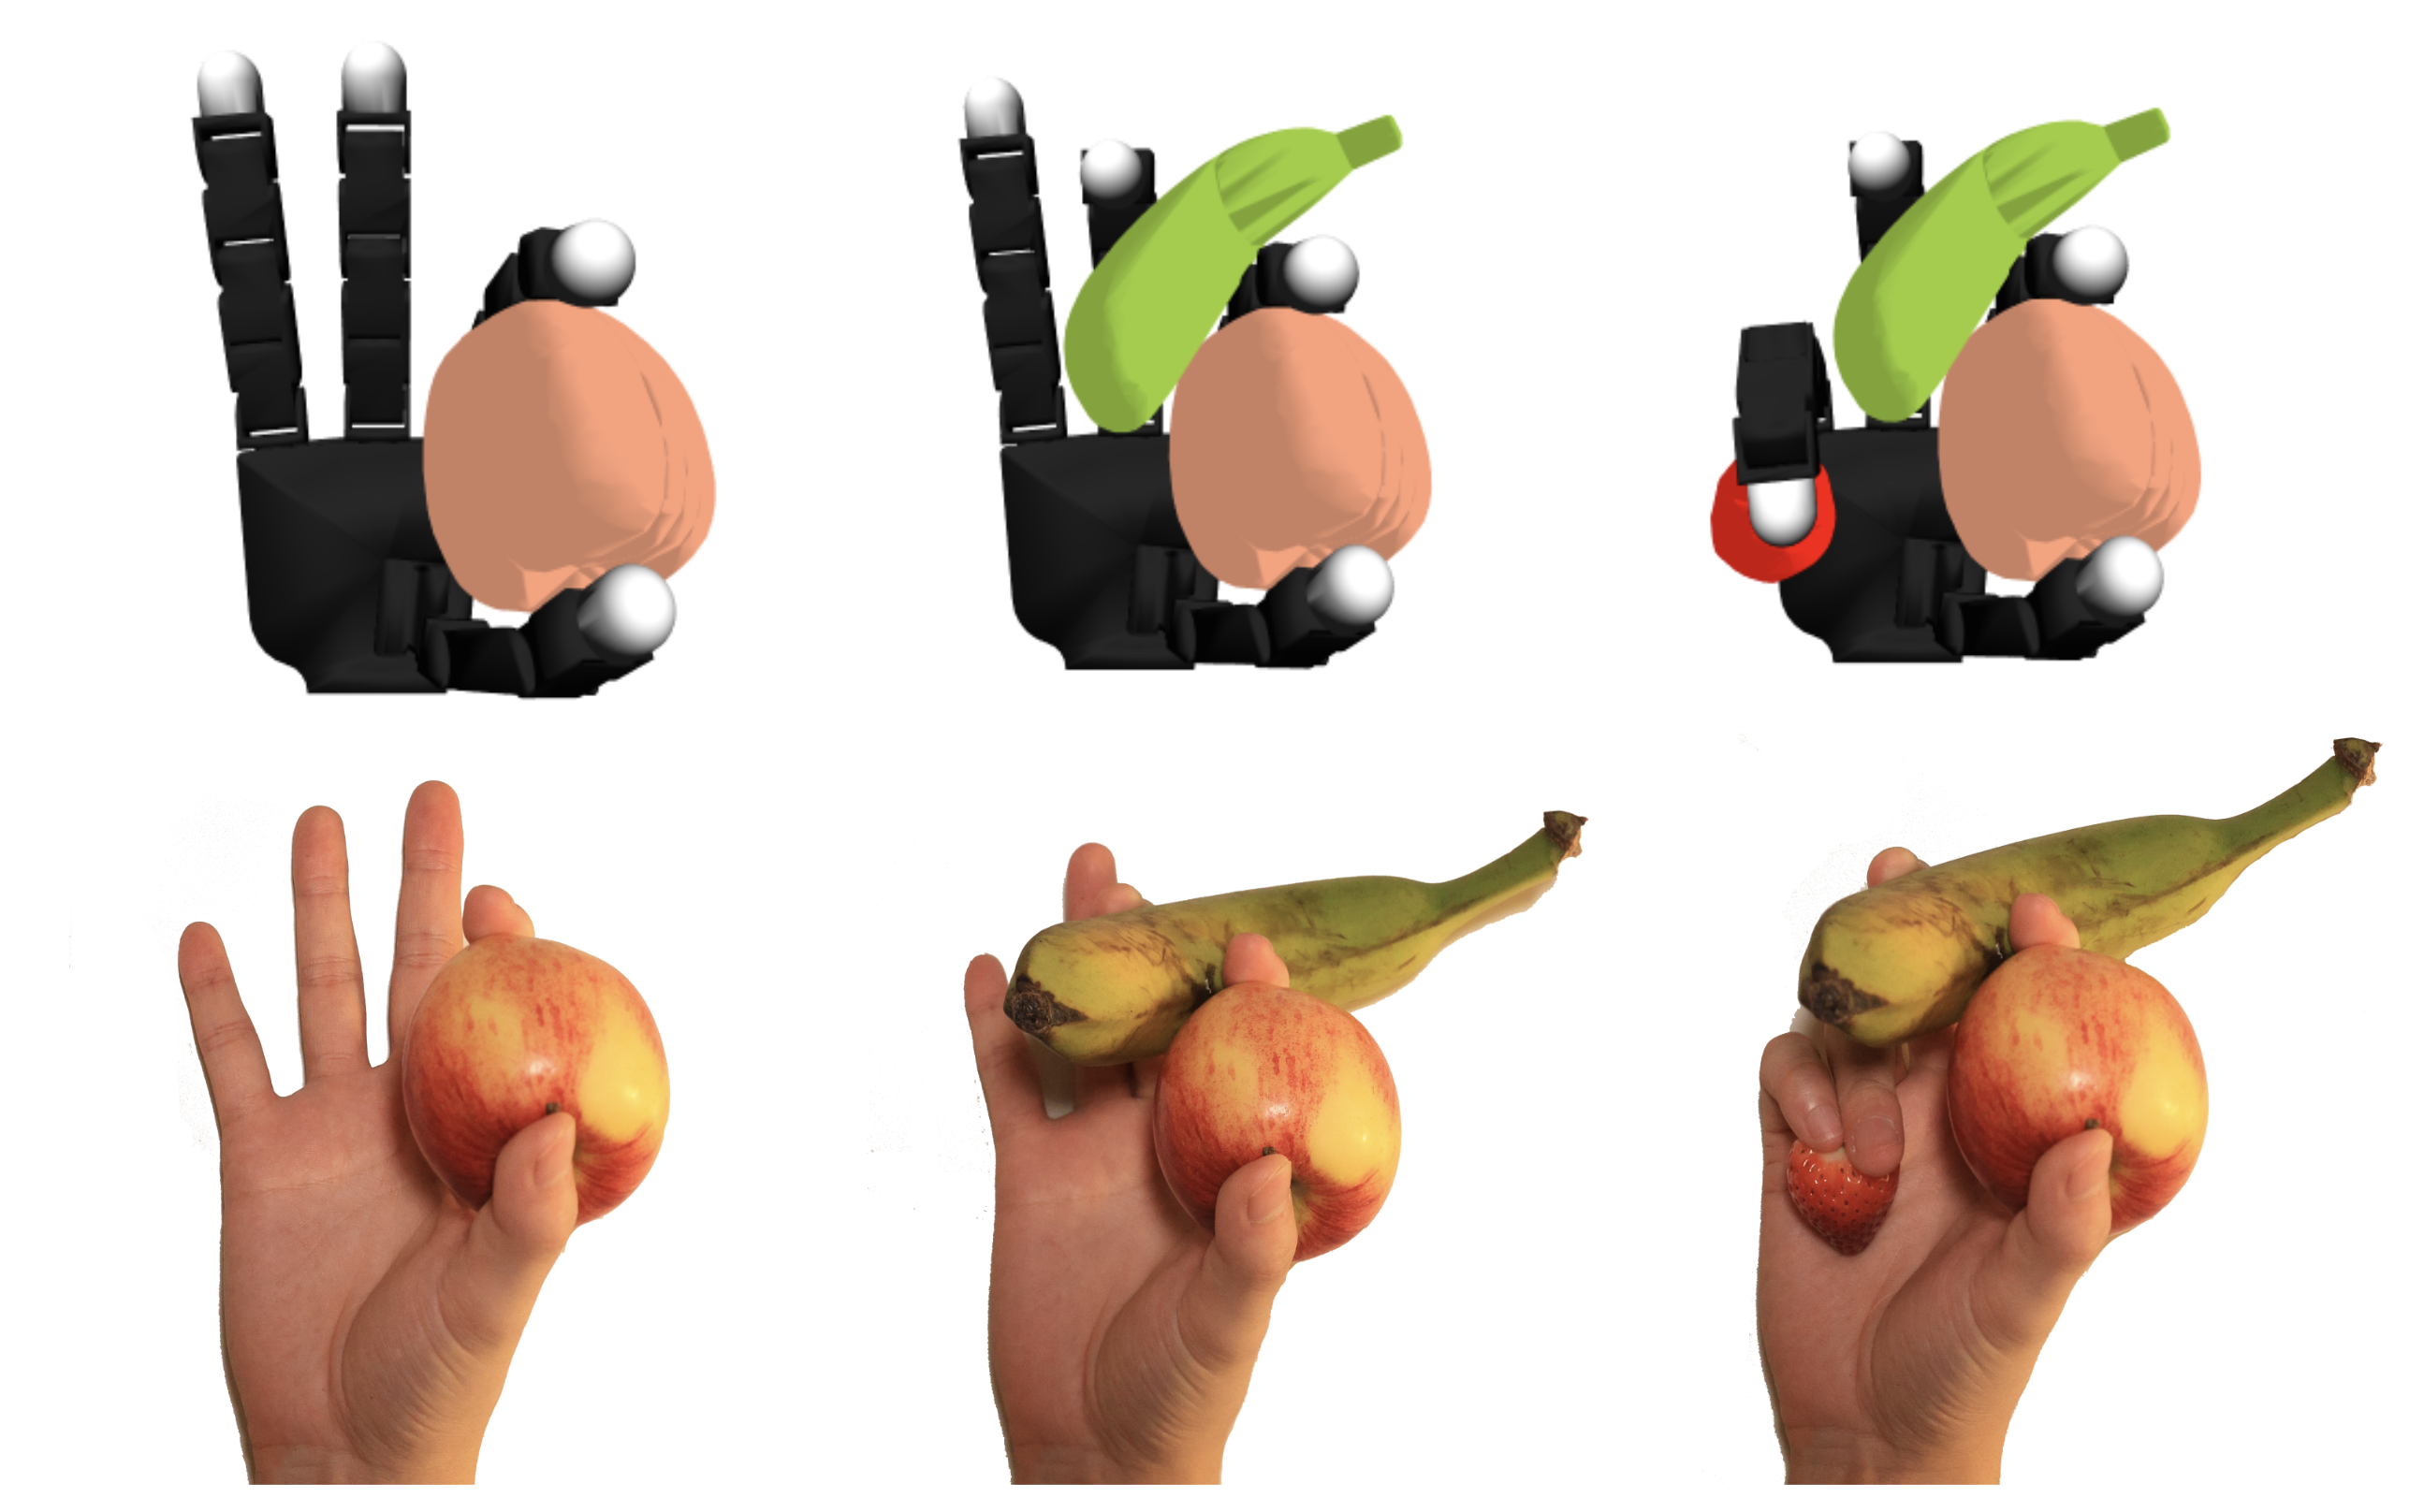
| Jun 03, 2026 | Our preprint MoDex: A Diffusion Policy for Sequential Multi-Object Dexterous Grasping is now on arXiv. The policy keeps adjusting the grasp to what the robot sees, so that a multi-fingered robot hand can pick up several objects in a row. |
| Jun 03, 2026 | I was an invited participant in the Dexterous Manipulation Roundtable on Benchmarking, Reproducibility, and Standards at ICRA 2026 in Vienna, convening leading organizations in robot manipulation (NIST, EPFL, Northwestern, King’s College London, Shadow Robot). |